publications
2026
 Optimal Functional Incentives for Control: The Linear-Quadratic Case with Bilinear Incentives2026 IEEE Conference on Decision and Control (CDC), Dec 2026
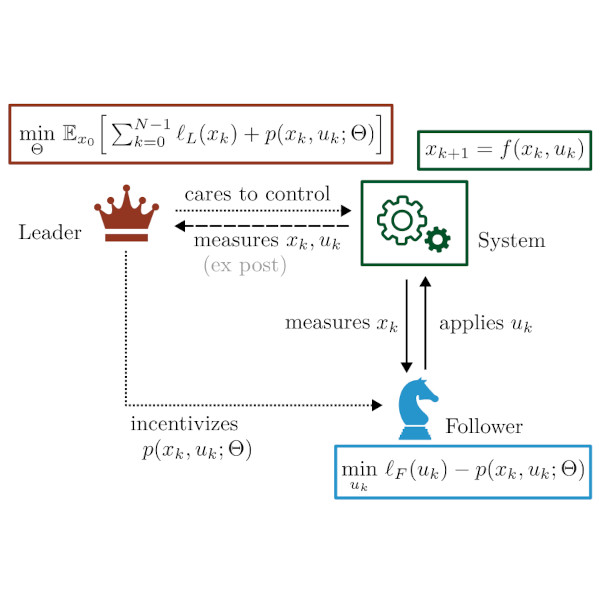
We study the design of functional incentive mechanisms for dynamical systems, in which a leader designs a fixed incentive function to motivate a self-interested follower to actuate the system beneficially over an extended horizon, without real-time revision of the incentive. This stands in contrast to the adaptive paradigm, in which the incentive is itself a continuously updated control variable. We formalize the problem as a discrete-time bi-level optimal control problem and derive analytical results for the linear-quadratic case with bilinear incentives and a myopic follower. Specifically, we establish a necessary and sufficient stability condition for the induced closed-loop system, derive a closed-form expression for the gradient of the expected leader cost with respect to the incentive parameter matrix, and obtain a fully closed-form cost expression in the scalar setting. Based on the latter, explicit characterizations of the optimal incentive parameter are provided in two asymptotic regimes: the infinite-horizon limit and the limit of high follower cost. For long horizons, the optimal incentive is shown to become independent of the follower’s private cost parameter, with direct implications for robust mechanism design under private information.
@inproceedings{mattOptimalFunctionalIncentives2026, title = {Optimal {{Functional Incentives}} for {{Control}}: {{The Linear-Quadratic Case}} with {{Bilinear Incentives}}}, shorttitle = {Optimal {{Functional Incentives}} for {{Control}}}, booktitle = {2026 {{IEEE Conference}} on {{Decision}} and {{Control}} ({{CDC}})}, author = {Matt, Jonas G. and Bolognani, Saverio and D{\"o}rfler, Florian}, year = {2026}, month = dec, eprint = {2604.27770}, primaryclass = {eess}, archiveprefix = {arXiv} }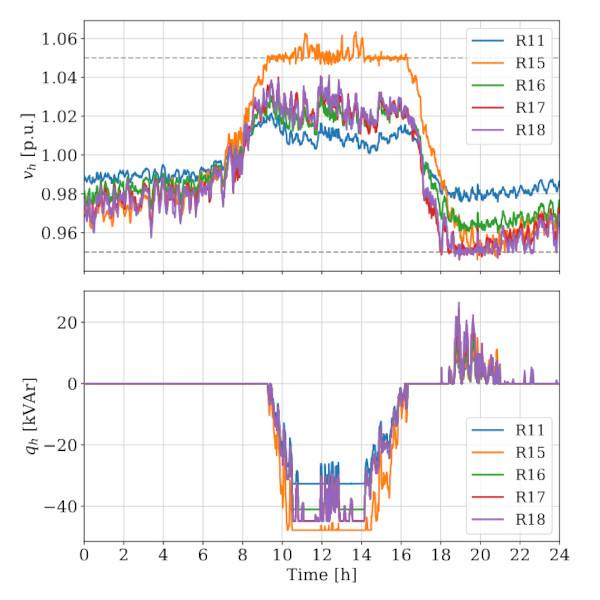 From Droop to Optimality: The Potential of Volt/Var Control for Power Distribution Grid EnhancementSustainable Energy, Grids and Networks, Sep 2026
When high amounts of active power are injected into power distribution grids, the overall power flow is limited because voltages reach their upper acceptable limits. Volt/var control aims to raise this power flow limit without physically reinforcing the grid but by controlling the voltage using reactive power. We use real consumption and generation data on a low-voltage CIGRÉ grid model and an experiment on a real distribution grid feeder to analyze how different volt/var methods can enhance the grid. We show that local droop control enhances the grid but underutilizes the reactive power resources. We discuss how this inefficiency can be partly reduced by fine-tuning the droop curves through data-driven techniques but illustrate that inherent trade-off persist for any local control method. We finally demonstrate that coordinated control methods can track the optimal solution and enhance the grid to its full potential if grid-wide communication is available. Our numerical study over a whole year of real data suggests that coordinated volt/var control can enable another 10.4% of maximum active power injections compared to droop control. In a small-scale real-life experiment, coordinated control enhanced the grid by the same amount.
@article{mattDroopOptimalityPotential2026, title = {From Droop to Optimality: The Potential of Volt/Var Control for Power Distribution Grid Enhancement}, author = {Matt, Jonas G. and Ortmann, Lukas and Bolognani, Saverio and D{\"o}rfler, Florian}, year = {2026}, month = sep, journal = {Sustainable Energy, Grids and Networks}, volume = {47}, pages = {102379}, issn = {2352-4677}, doi = {10.1016/j.segan.2026.102379} }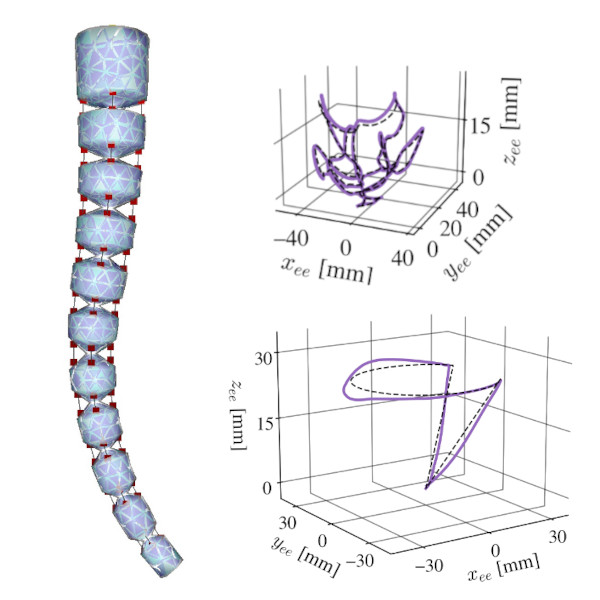 Data-Driven Soft Robot Control via Adiabatic Spectral SubmanifoldsThe International Journal of Robotics Research, Jul 2026
The mechanical complexity of soft robots creates significant challenges for their model-based control. Specifically, linear data-driven models have struggled to control soft robots on complex, spatially extended paths that explore regions with significant nonlinear behavior. To account for these nonlinearities, we develop here a model-predictive control strategy based on the recent theory of adiabatic spectral submanifolds (aSSMs). This theory is applicable because the internal vibrations of heavily overdamped robots decay at a speed that is much faster than the desired speed of the robot along its intended path. In that case, low-dimensional attracting invariant manifolds (aSSMs) emanate from the path and carry the dominant dynamics of the robot. Aided by this recent theory, we devise an aSSM-based model-predictive control scheme purely from data. We demonstrate the effectiveness of this data-driven model on various dynamic trajectory tracking tasks on a high-fidelity and high-dimensional finite-element model of a soft trunk robot. Notably, we find that four- or five-dimensional aSSM-reduced models outperform the tracking performance of other data-driven modeling methods by a factor up to 10 across all closed-loop control tasks.
@article{kaundinyaDatadrivenSoftRobot2026, title = {Data-Driven Soft Robot Control via Adiabatic Spectral Submanifolds}, author = {Kaundinya, Roshan S. and Alora, John Irvin and Matt, Jonas G. and Pabon, Luis A. and Pavone, Marco and Haller, George}, year = {2026}, month = jul, journal = {The International Journal of Robotics Research}, doi = {10.1177/02783649261461630} } A Welfarist Perspective on Fair Generation CurtailmentarXiv preprint 2605.03860, May 2026
@misc{mattWelfaristPerspectiveFair2026,
  title = {A {{Welfarist Perspective}} on {{Fair Generation Curtailment}}},
  author = {Matt, Jonas G. and Shilov, Ilia and Bolognani, Saverio},
  year = {2026},
  month = may,
  number = {arXiv:2605.03860},
  eprint = {2605.03860},
  primaryclass = {eess},
  publisher = {arXiv},
  doi = {10.48550/arXiv.2605.03860},
  archiveprefix = {arXiv}
}
2025
 Lossless Compression of Time Series Data: A Comparative Study2025 IEEE 30th International Conference on Emerging Technologies and Factory Automation (ETFA), Sep 2025
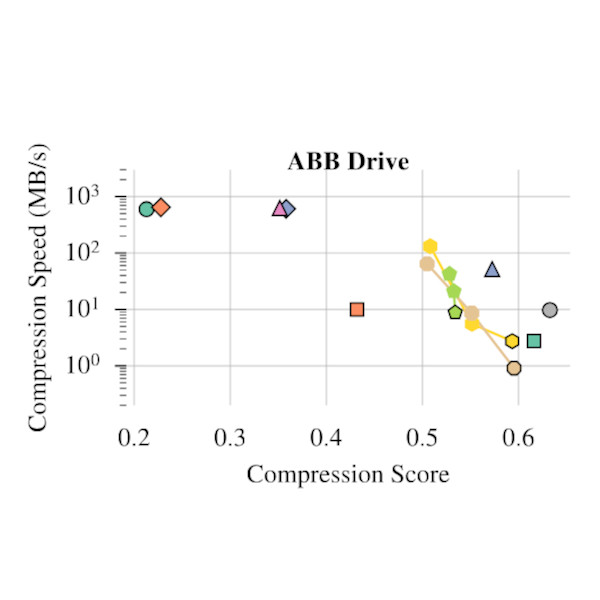
Our increasingly digital and connected world has led to the generation of unprecedented amounts of data. This data must be efficiently managed, transmitted, and stored to preserve resources and allow scalability. Data compression has therein been a key technology for a long time, resulting in a vast landscape of available techniques. This largest-to-date study analyzes and compares various lossless data compression methods for time series data. We present a unified framework encompassing two stages: data transformation and entropy encoding. We evaluate compression algorithms across both synthetic and real-world datasets with varying characteristics. Through ablation studies at each compression stage, we isolate the impact of individual components on overall compression performance–revealing the strengths and weaknesses of different algorithms when facing diverse time series properties. Our study underscores the importance of well-configured and complete compression pipelines beyond individual components or algorithms; it offers a comprehensive guide for selecting and composing the most appropriate compression algorithms tailored to specific datasets.
@inproceedings{mattLosslessCompressionTime2025a,
  title = {Lossless {{Compression}} of {{Time Series Data}}: {{A Comparative Study}}},
  shorttitle = {Lossless {{Compression}} of {{Time Series Data}}},
  booktitle = {2025 {{IEEE}} 30th {{International Conference}} on {{Emerging Technologies}} and {{Factory Automation}} ({{ETFA}})},
  author = {Matt, Jonas G. and Huang, Pengcheng and Maag, Balz},
  year = {2025},
  month = sep,
  pages = {1--8},
  issn = {1946-0759},
  doi = {10.1109/ETFA65518.2025.11205560}
}